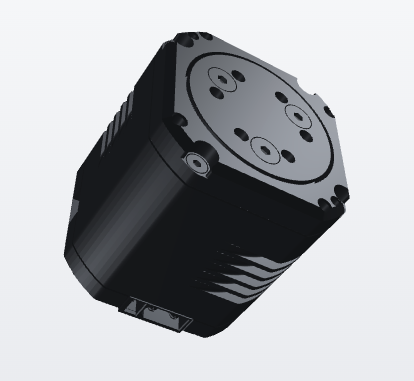
JM055
- Peak torque
- 55 N·m
- Rated torque
- 17 N·m
- Weight
- 465 g
- Dimensions
- ø58×57.4 mm
- Rated speed
- 120 rpm
- Gear ratio
- 36
Highlights
Compact and light
ø58×57.4 mm / 465 g
High torque density
Peak torque density of 118 N·m/kg
Precise positioning
Repeatability ≤±0.01°, backlash within 15 arcmin
Smooth running
Torque fluctuation ≤5%, no jerk
Quiet operation
Noise <60 dB(A)
Integrated output bearing
Crossed-roller bearing + four-point contact bearing
Protection and force control
Over-temperature, over/under-voltage and over-current protection, stall protection, plus hybrid force/position and torque control
Industrial fieldbus
CAN2.0 / CAN FD bus, 48 V DC supply
Specifications
Model: JM055
Mechanical
- Dimensions
- ø58×57.4 mm
- Weight
- 465 g
- Hollow shaft bore
- None
- Encoder type
- Dual encoder
- Peak torque density
- 118 N·m/kg
- Reducer type
- Two-stage planetary reducer
- Gear ratio
- 36
- Backlash
- 15 arcmin
- Bearing type
- Crossed-roller bearing + four-point contact bearing
Electrical & Performance
- Rated torque
- 17 N·m
- Peak torque
- 55 N·m
- Rated speed
- 120 rpm
- Peak speed
- 80 rpm
- Rated voltage
- 48 V DC
- Rated phase current
- 6.07 Arms
- Rated DC bus current
- 7 Arms
- Rated efficiency
- 68%
- Torque ripple (FFT)
- ≤5%
- Peak phase current
- 27.65 Apeak
- Torque fluctuation
- ≤5%
- No-load speed
- 192 rpm
- Cogging torque
- <0.055 N·m
- Back-EMF total harmonic distortion
- ≤5%
- Torque constant
- 1.99 N·m/Arms
Control & Communication
- Communication
- CAN2.0 / CAN FD
- Positioning accuracy
- ≤0.01°
- Repeatability
- ≤±0.01° + backlash
- Hybrid force/position control
- Supported
- Torque control
- Supported
Reliability
- Noise (at 50 cm)
- <60 dB(A)
- Over-temperature / over- and under-voltage / over-current protection
- Supported
- Stall protection
- Supported
Dimensions
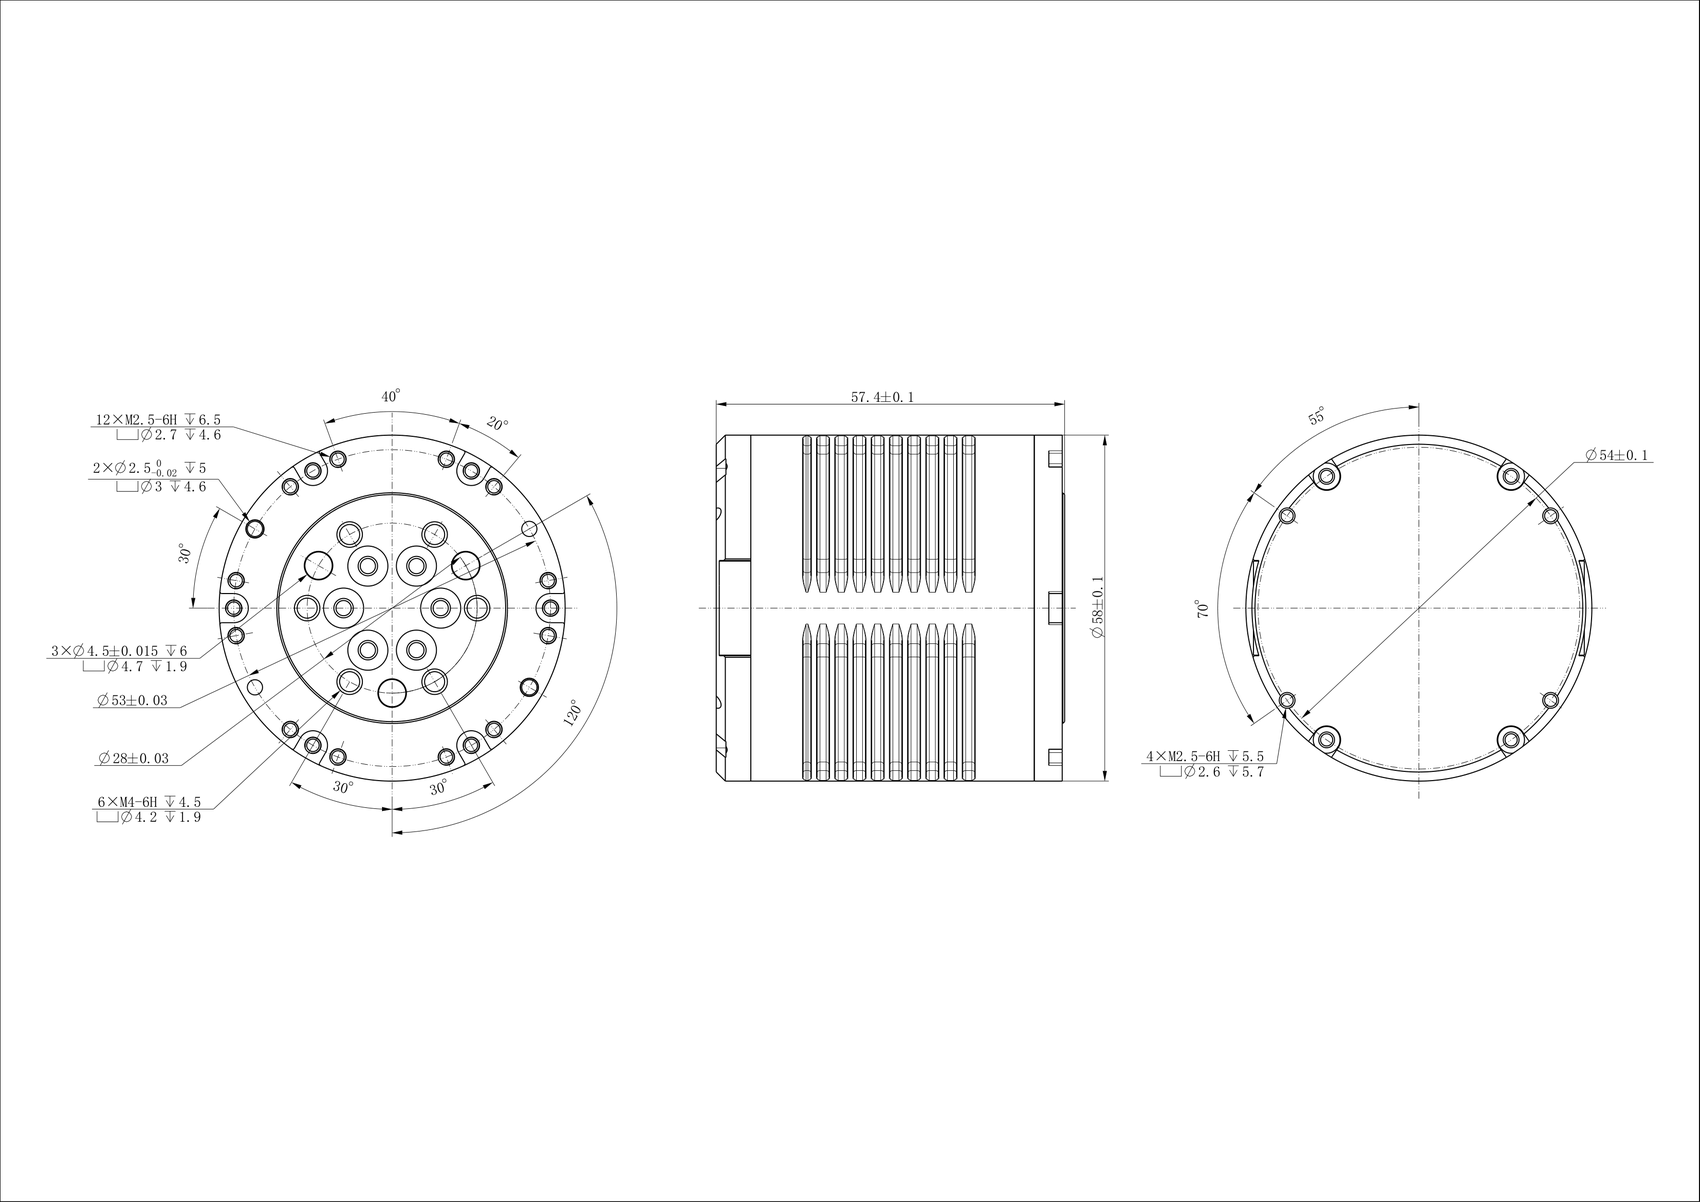
Outline drawing